

Lei Ye (Raymon Yip) @MasterYip3
PHD at Shanghai Institude of Technology (SII) & HIT Research Intern at Roboparty Lab AI & Robotics github.com/MasterYip China Joined February 2023-
Tweets23
-
Followers99
-
Following296
-
Likes58
Different from motion planning and tracking, I-BFM uses FB representation to handle the box-carrying task. In the demonstration, the robot performs the pick-and-place task without palpable phase switching. FB makes the whole task into a "higher-level optimal control problem" that aims to move the box to the goal in any way with the lowest "energy".
Can humanoids recover in interaction tasks? 📦🤖 Excited to share I-BFM! Reward-conditioned policy: carry, push, kick. FB: robot–object–contact dynamics; LOGO: contact now → task goal later. G1 MuJoCo Carry: 94.3% → 89.3% after robot disturbance. 🌐 iamhardworking.github.io/I-BFM/
3DGS looks real—until you shift the camera or insert a car. 🚗 Excited to unveil SPVC, our joint work with @GWMGlobal! 4 upgrades to photorealistic driving video fixing: 🔹 Structured: Geometry-guided, not unconstrained. 🔹 Panoptic: Background + foreground, not just one. 🔹 Video: Temporally consistent, not frame-by-frame. 🔹 Cross-Dataset: One model across Waymo, nuScenes & PandaSet. One unified video diffusion fixer. See the difference! 👇 📄 Paper: arxiv.org/pdf/2608.17420 🌐 Project: li00147.github.io/SPVC-Project-P…
SGS shows unbelievable results in locomotion, it learns locomotion skills& behaviors without motion references
Our manipulation results were mind-blowing the first time I saw them, but earlier on, my favorite result was this locomotion run. Many great people have done parkour-type skills with locomotion already, but as far as I am aware, most, if not all, of these works trained separate
Our manipulation results were mind-blowing the first time I saw them, but earlier on, my favorite result was this locomotion run. Many great people have done parkour-type skills with locomotion already, but as far as I am aware, most, if not all, of these works trained separate policies for each terrain, and then distilled into a single policy. They also typically contained tons of hand-engineered rewards and curriculums. A very early motivation for SGS was to simply figure out if we could get similar results but get rid of as much of this hand-engineering as possible, and we managed to achieve that! This video shows a continuous 1-min run in much harder terrains than ever before, all solved by the same policy.
@ElijahGalahad the anymal example is Amazing too

imagine you can reject papers as a reviewer to win money?
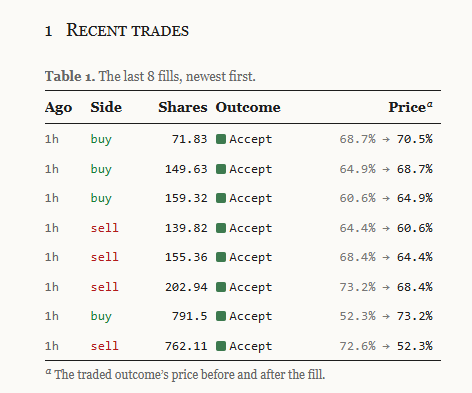
A prediction market for peer review. Have we reached peak AI? 🤔

@newcomm Strongly recommand Unitree add Thor to their G1 configuration lol.
Can humanoid motion generation and control be unified in a single policy? PredActor uses a single end-to-end diffusion policy rather than separate motion generation and tracking. With proprioceptive feedback, it predicts internal future states and directly outputs actions at 50 Hz onboard a Unitree G1. Text-conditioned motion, joystick steering, disturbance response, and semantic interpolation are supported in the single policy. Project Page: masteryip.github.io/predactor.gith…
@mateoguaman truly amazing!Are there reference motions used for training? or it learns by it self about how to handle different type of terrains?
@ChenTessler many thanks for your feed back! I will refine the positioning of our data collection and training pipeline more precisely as soon as possible!
More Demonstration in MuJoCo Simulator, including Target tracking, Text Control, Text-Joy Combined Control, Disturbance. Mujoco evaluation codes can be found at the Repo: github.com/MasterYip/Pred…
PredActor supports Semantic Interpolation too:
@NliGjvJbycSeD6t Too Thrilled to Star!
More resources can be found: Project: masteryip.github.io/predactor.gith… GitHub: github.com/MasterYip/Pred… arXiv: arxiv.org/abs/2609.24840 HF: huggingface.co/MasterYip/Pred… YouTube: youtu.be/joIE_Iu7sPY?si… Discord Community: discord.gg/3ZsNAvzxZy
Unlike a motion-generator-plus-tracker pipeline, it uses proprioceptive feedback to jointly predict executable actions and an internal future-state trajectory. Only actions are executed; predicted states remain inside the policy as a guidance interface. Classifier-free guidance strengthens text-conditioned behaviors, while classifier guidance steers predicted states toward test-time objectives. Everything can be fully executed on Jetson Orin NX at 50 Hz.
@ChongZzZhang I've seen the recording the film at sii few weeks ago
@qiayuanliao This made me thought of something

Well Soar @SoarWell
75 Followers 7K Following
Sniffer_sun @Sniffer_sun
151 Followers 5K Following
dharv @justwaitinganon
18 Followers 16 Following
Kai @Ka1_Q1a0
8 Followers 272 Following


Harold @wahoo_harold
294 Followers 3K Following Making 🤖 + ⚽ a reality at @UvA_Amsterdam / 日本茶 / 語学 / 邦ロック / モンハン
xiaoshi @xiaoshitree
103 Followers 3K Following I'm Studying RL now and pushing myself to express in English/Japanese instead of 中文. I wanna explore more vast world.

Nguyen Chuong @NguyenC21046292
4 Followers 69 Following
Thorbjørn Rønje @thorbjornron
2K Followers 3K Following Building companies, AI infrastructure & the post-labor future | GP & Co-Founder @ Bifrost Studios & Hyperion.
Domingo @Domingo_Yue
0 Followers 313 Following

RUOYU GENG @janeandrebecca
0 Followers 82 Following

Anshuman Lall @ NeurI... @anshuman1
518 Followers 4K Following LLM Post-Training/ Recursive Self-Improvement for Reasoning Co-founder/ MTS @ReasonCoreAI PhD @UCLA, Bachelors @iitbombay Led a team of ~500 PhD researchers
leo @leohurryup
1 Followers 68 Following
MintyLemon @mintyLem0n
26 Followers 515 Following
Rishabh Jain @RishabhJain_r
341 Followers 3K Following ML & Robotics @Columbia | prev intern @TactaSystems
Tong @TongAC05
1 Followers 75 Following

stephen @_ildsjel
258 Followers 2K Following idle vapourings of a mind diseased | deploying rl @ apptronik
ydy0427 @ydy042771580
0 Followers 150 Following
Jaspal Singh @JaspalS44414885
13 Followers 2K Following
autumn & winter ❄�... @V8DiI
9 Followers 766 Following robotics & embodied intelligence , aviation & space


King_andy @Kingand33493259
190 Followers 4K Following artist, engineer and polymath 🤓 #computerart #DataScience #ComputerVision #MachineLearning #Science #artist #ArtificialIntelligence #episTHEMology
Ziqi Han @HanZiqi666
11 Followers 29 Following Tongji University · RoboParty Lab | Humanoid robotics, robot–object interaction & unsupervised RL
Ankur Bohra @AnkurBohra9
66 Followers 7K Following
TheSilentCartographer @OfficialAureleo
132 Followers 600 Following 4x DGX Sparks | Local AI | Mapping the path to the future

Felix @FelixLi0323
2 Followers 66 Following
Chen Tessler @ChenTessler
3K Followers 681 Following Research Scientist @NVIDIAAI ; Training humanoids 🤖 ; Reinforcement learning PhD @TechnionLive 🇮🇱. Views are my own.
Zhen Wu @zhenkirito123
2K Followers 422 Following Amazon FAR (Frontier AI & Robotics). CS @Stanford. Humanoid Robots & Character Animation 🤖
Ganon @GX0704
0 Followers 89 Following
Rajiv Patel-O’Conno... @rajivpoc
6K Followers 3K Following general partner @hiframework. views my own, nfa
enes @bearerjwt
2 Followers 501 Following
Bhagyesh Kumar @invi_bhagyesh
705 Followers 7K Following "it should be raining" mathematics ∩ AISafety, sophomore, I play dice working w/ @lionellevine, exchange @USTC

ζ Pedram ζ @zenstyle
810 Followers 7K Following Artificial Intelligence. Quantum. Distributed Learning. Cybernetics. Kung Fu. Blockchain. Networks. Sensor Perception and Robotics.
Haiyun Zhang @HaiyunZhan36513
47 Followers 149 Following Haiyun Zhang is a Ph.D. in @texas_robotics at @UTAustin . X posts his engineering projects backup. Ongoing works may not be posted, but feel free to DM.

Kun Tao @KunTao221218
44 Followers 1K Following Robotics & AI, anything interesting, study @TU_Muenchen, work @TUM_MIRMI, co-w @CMU_Robotics
Minh Tài @tai_minh01247
16 Followers 2K Following
Edward Fang @Nbhunte
6 Followers 336 Following
Zhi Su @ZhiSu22
2K Followers 350 Following Undergrad @Tsinghua_IIIS | 🤖 Robot Learning | Incoming PhD @UCBerkeley
Zixian Liu @ZixianLiu03
96 Followers 301 Following 1st PhD student @unccs, prev undergrad @Tsinghua_Uni
Zion Guo @guo_zhong8838
5 Followers 403 Following
Alex YiHuang @AlexHuangRP
15 Followers 2 Following
Ziqi Han @HanZiqi666
11 Followers 29 Following Tongji University · RoboParty Lab | Humanoid robotics, robot–object interaction & unsupervised RL
Rosario Scalise @rosario_scaling
131 Followers 325 Following Doin RL, sim2real, controls, ML, and science. PhD from @uwcse. Prev @cmu_robotics
Sitan Chen @sitanch
2K Followers 219 Following assistant professor of computer science @hseas, learning theorist, 🎹
铁卫士 @tieweishi
8 Followers 256 Following

Kosta Derpanis @CSProfKGD
88K Followers 202 Following #CS Associate Prof @YorkUniversity #ComputerVision Researcher, @VectorInst Affiliate @UofT status only, @ELLISforEurope Member, X-social media chair 4all vision

Sher.X @sheryl_xwx
12 Followers 292 Following Marketing & PR & Ecosystem. @RoboParty_DEV Open-source humanoids
Anshuman Lall @ NeurI... @anshuman1
518 Followers 4K Following LLM Post-Training/ Recursive Self-Improvement for Reasoning Co-founder/ MTS @ReasonCoreAI PhD @UCLA, Bachelors @iitbombay Led a team of ~500 PhD researchers
Rishabh Jain @RishabhJain_r
341 Followers 3K Following ML & Robotics @Columbia | prev intern @TactaSystems

He Wang @HughWang19
2K Followers 153 Following Assistant Professor of Computer Science at Peking University, Founder and CTO of Galbot.
Hang Zhao @zhaohang0124
6K Followers 1K Following Asst. Prof@ Tsinghua University, Co-founder @GalaxeaDynamics. Former Scientist@Waymo, MIT PhD’19. I research on multimodal learning, self-driving and robotics!
Mohamad H. Danesh @mo_danesh
296 Followers 844 Following phd @McGillU and @mila_quebec, working on rl and robot learning / ex- @LetsUnifyAI, @NUSComputing, @EngineeringOSU
Minghao Fu @Minghao__Fu
261 Followers 243 Following Ph.D. Student @UCSanDiego | World Model | Representation Learning |
Archon Robotics @Archon_Robotics
703 Followers 9 Following From Origin, Through Action, Toward the Future.
earwulf @earwulf
4K Followers 3K Following
Shuang Li @ShuangL13799063
8K Followers 1K Following Research Scientist @GoogleDeepMind. Founding Member @VoyageAI, Postdoc @Stanford, PhD @MIT. #Robotics #Agent
Isabelle Augenstein @IAugenstein
12K Followers 1K Following Full Professor @CopeNLU @uni_copenhagen. Formerly @ucl_nlp, @SheffieldNLP. Explainable AI, Natural Language Processing, ML.
Hongyang Li @francislee2020
1K Followers 169 Following Co-founder of Archon @archon_robotics. Assistant Prof @HKUniversity. I direct @OpenDriveLab. We only live once, if we do it right, once is enough.
Chengkun Li @ckli85
542 Followers 330 Following 🇨🇭phd student @EPFL_en | working on embodied ai and computational neuroscience | previous sr at google, bytedance | open science
China Xinhua News @XHNews
11.4M Followers 79 Following Public media for public good. We don't pursue corporate interests, nor yield to pressure of ideological stigmatization and political bias Our App: https://t.co/uYjoablw4w
Mateo Guaman Castro @mateoguaman
963 Followers 678 Following 🤖 · 🚵♂️ · 🎸 · 🇪🇨 PhD student @uwcse currently kicking it at @FlexionAI, working on scaling RL. I like biking long distances and playing the bass.
Chen Tessler @ChenTessler
3K Followers 681 Following Research Scientist @NVIDIAAI ; Training humanoids 🤖 ; Reinforcement learning PhD @TechnionLive 🇮🇱. Views are my own.
Jiafei Duan @DJiafei
8K Followers 1K Following Assistant Professor at @NUScomputing | Robotics & AI PhD @uwcse | Host of @RoboPapers | Ex-@allen_ai robotics lead, @NVIDIA | Magician | my opinion is my alone.
Haiyun Zhang @HaiyunZhan36513
47 Followers 149 Following Haiyun Zhang is a Ph.D. in @texas_robotics at @UTAustin . X posts his engineering projects backup. Ongoing works may not be posted, but feel free to DM.
Bhagyesh Kumar @invi_bhagyesh
705 Followers 7K Following "it should be raining" mathematics ∩ AISafety, sophomore, I play dice working w/ @lionellevine, exchange @USTC
Akihisa Watanabe @Akihisa_Wat
699 Followers 2K Following MSc student in Computer Science @waseda_univ | Humanoid Robots & Character Animation | Intern @MIT, Visiting @CarnegieMellon
Daesik Kim @chuckguhaja
72 Followers 250 Following Head of Webtoon AI, Naver Webtoon. Ph.D. Former CEO of ai startup acquired by Naver Webtoon.
Dvij Kalaria @DvijKalaria
995 Followers 677 Following PhDing @UCBerkeley @berkeley_ai | Interning @nvidia GEAR | MS @CMU_Robotics | UG @IITKgp | Research in Robot Learning
ζ Pedram ζ @zenstyle
810 Followers 7K Following Artificial Intelligence. Quantum. Distributed Learning. Cybernetics. Kung Fu. Blockchain. Networks. Sensor Perception and Robotics.
Kun Tao @KunTao221218
44 Followers 1K Following Robotics & AI, anything interesting, study @TU_Muenchen, work @TUM_MIRMI, co-w @CMU_Robotics
mansin @Mankaran32
8K Followers 864 Following Building @eyecandyrobots Built @flowdrive_ai role models @realGeorgeHotz & @iSidhuMoosewala
Zixian Liu @ZixianLiu03
96 Followers 301 Following 1st PhD student @unccs, prev undergrad @Tsinghua_Uni
Dima Damen @dimadamen
12K Followers 781 Following Professor of Computer Vision, @bristolcs. Senior Staff Research Scientist @GoogleDeepMind - passionate about the temporal stream in our lives.

Kevin K. Yang 楊凱�... @KevinKaichuang
24K Followers 6K Following Principal Researcher in BioML @MSFTResearch (@MSRNE). He/him/他. 🇹🇼
Patrick Walters @wpwalters
6K Followers 375 Following cheminformatics, machine learning, drug discovery, opinions
CnEVPost @CnEVPost
33K Followers 221 Following China EV news, data, insights and more. Telegram: https://t.co/2fzq9AMRNz Newsletter: https://t.co/scncnqxkNY Google News: https://t.co/0Xe3cv6HMP
JCIM & JCTC Journals @JCIM_JCTC
11K Followers 981 Following Tweets from Journal of Chemical Information and Modeling (JCIM) and Journal of Chemical Theory and Computation (JCTC) from @ACSPublications
Olexandr Isayev 🇺�... @olexandr
10K Followers 4K Following #CompChem Prof @CMU_Chem. Connecting chemical sciences with AI & #MachineLearning. #tarheels fan. Care:#design, #photography #Ukraine #cats🐈 Rants are mine
Ingo Hartung @HartungIngo
17K Followers 806 Following discovery chemistry nerd @Merckgroup; oncology, immunology, targeted protein degradation, ADCs; soccer, politics, tapas can slip into the feed; my own views
Andrew White 🐦�... @andrewwhite01
34K Followers 2K Following Automating science. Cofounder @EdisonSci. Cofounder @FutureHouseSF. Former prof of chem eng.
New Scientist @newscientist
4.3M Followers 278 Following The best place to find out what’s new in science – and why it matters.You might like


















